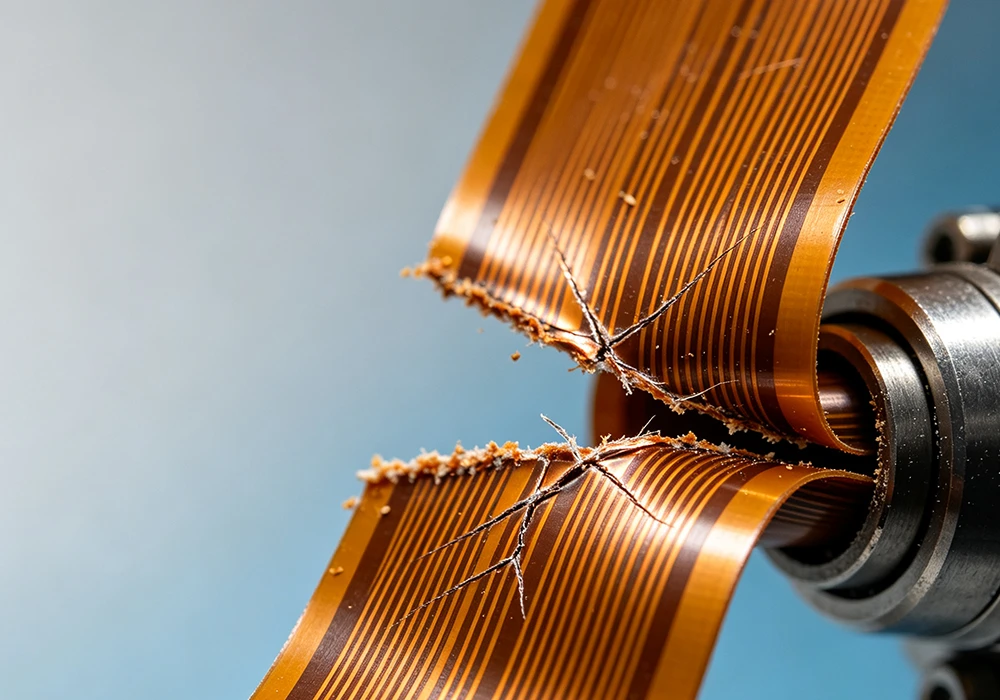
Movement and Connector Strain
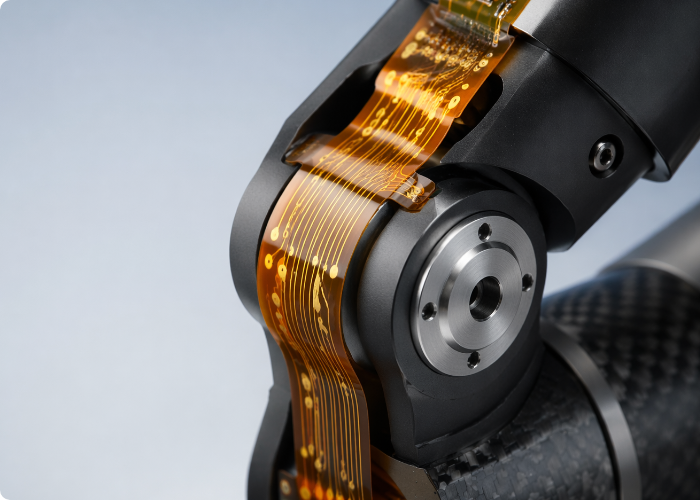
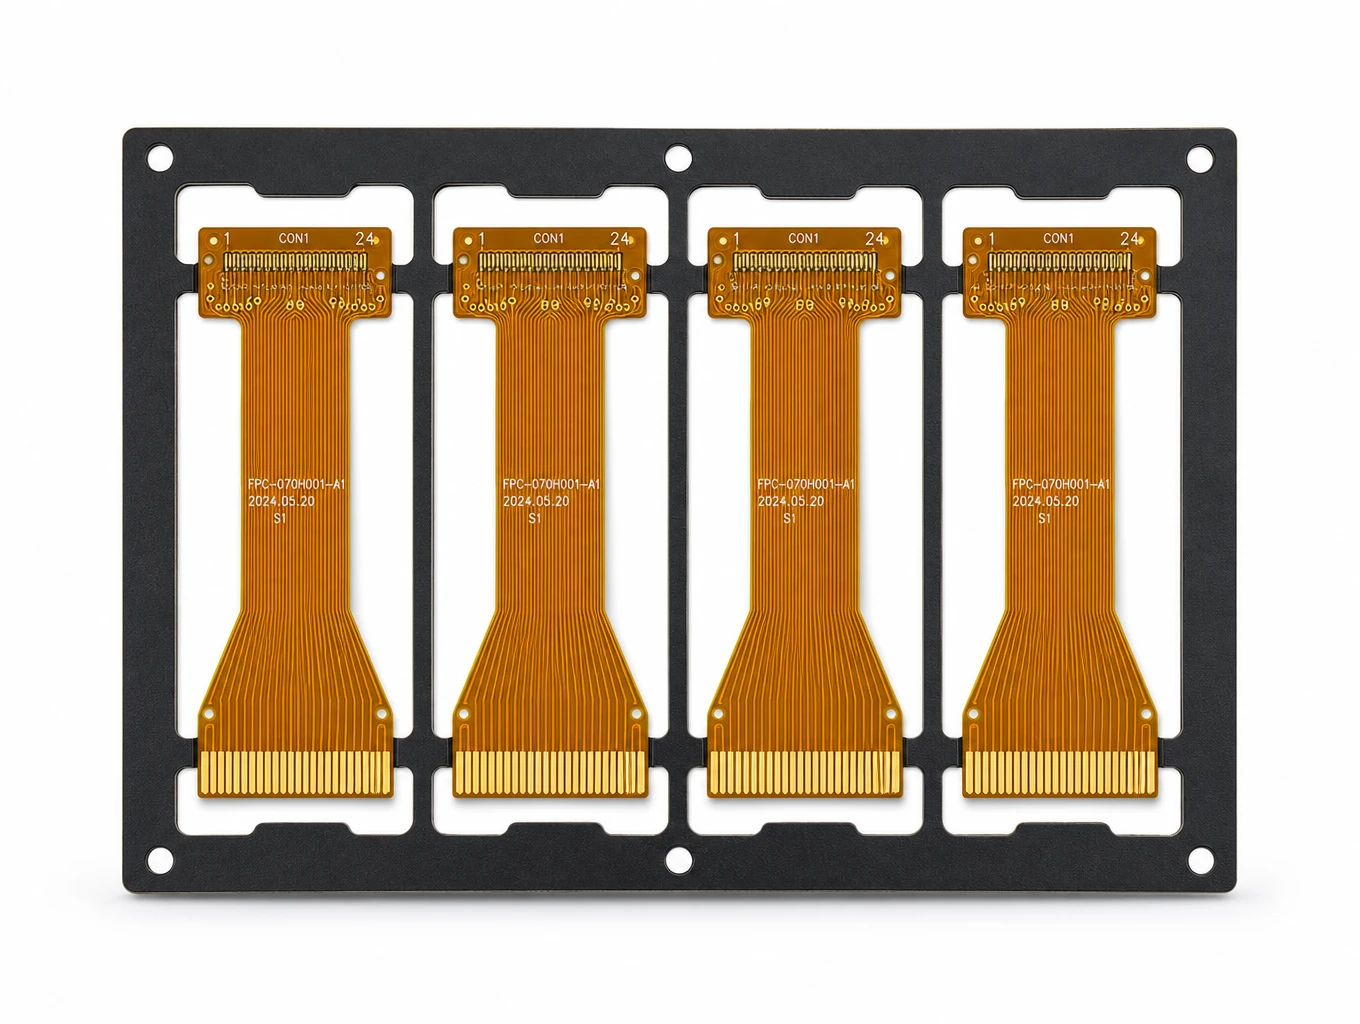
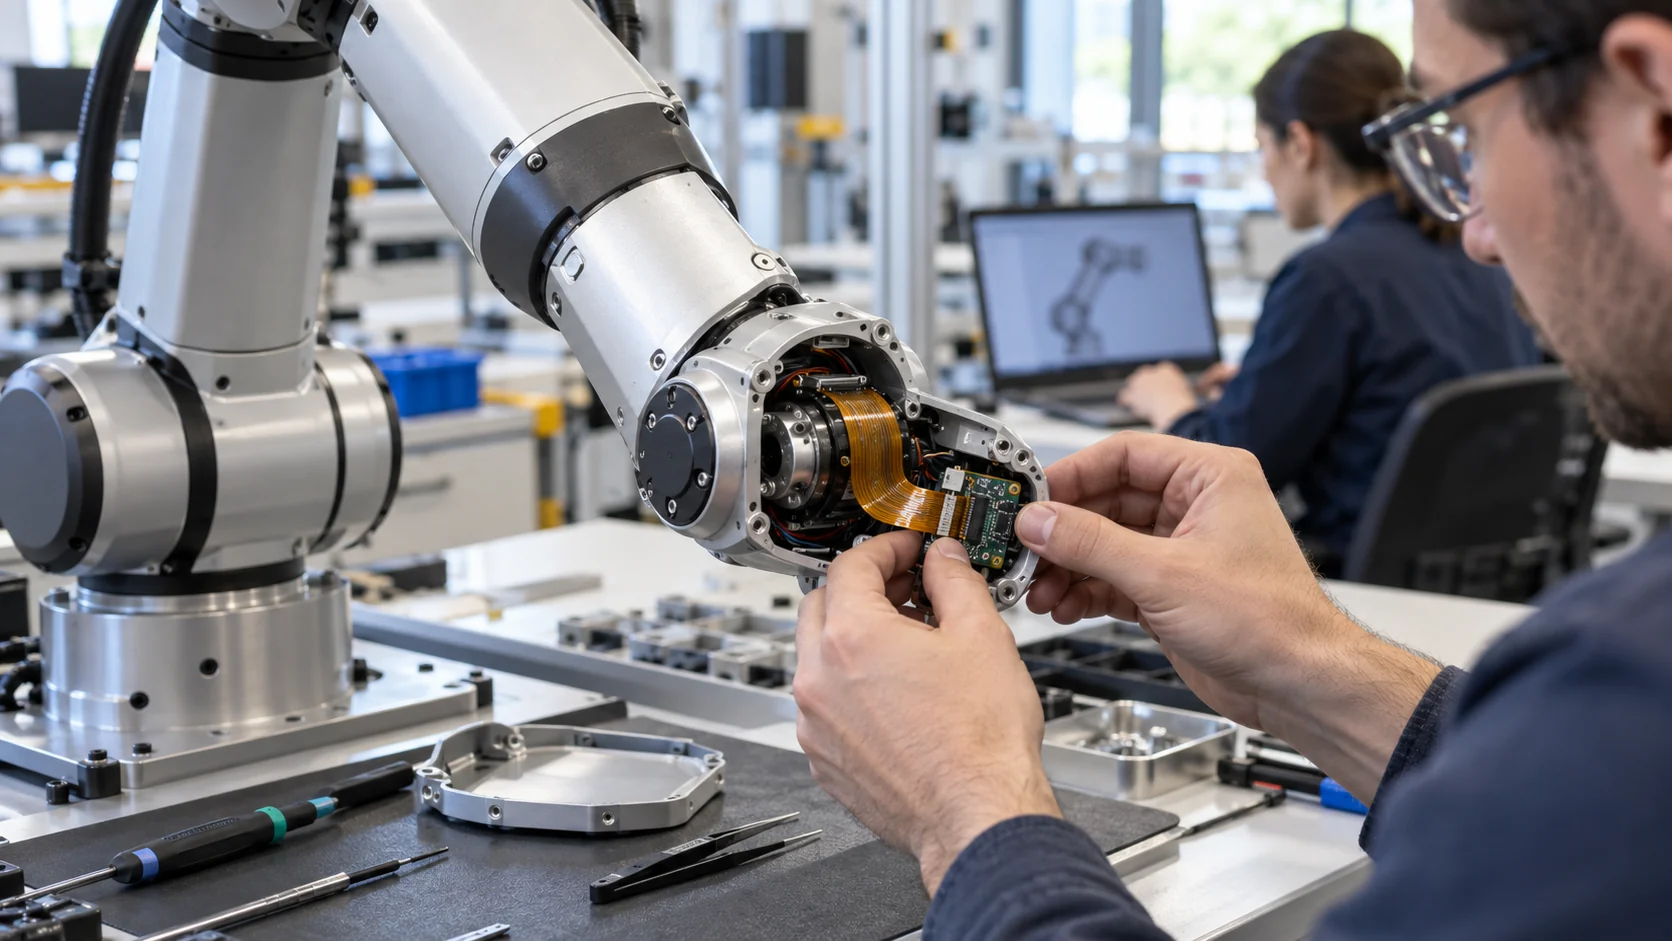
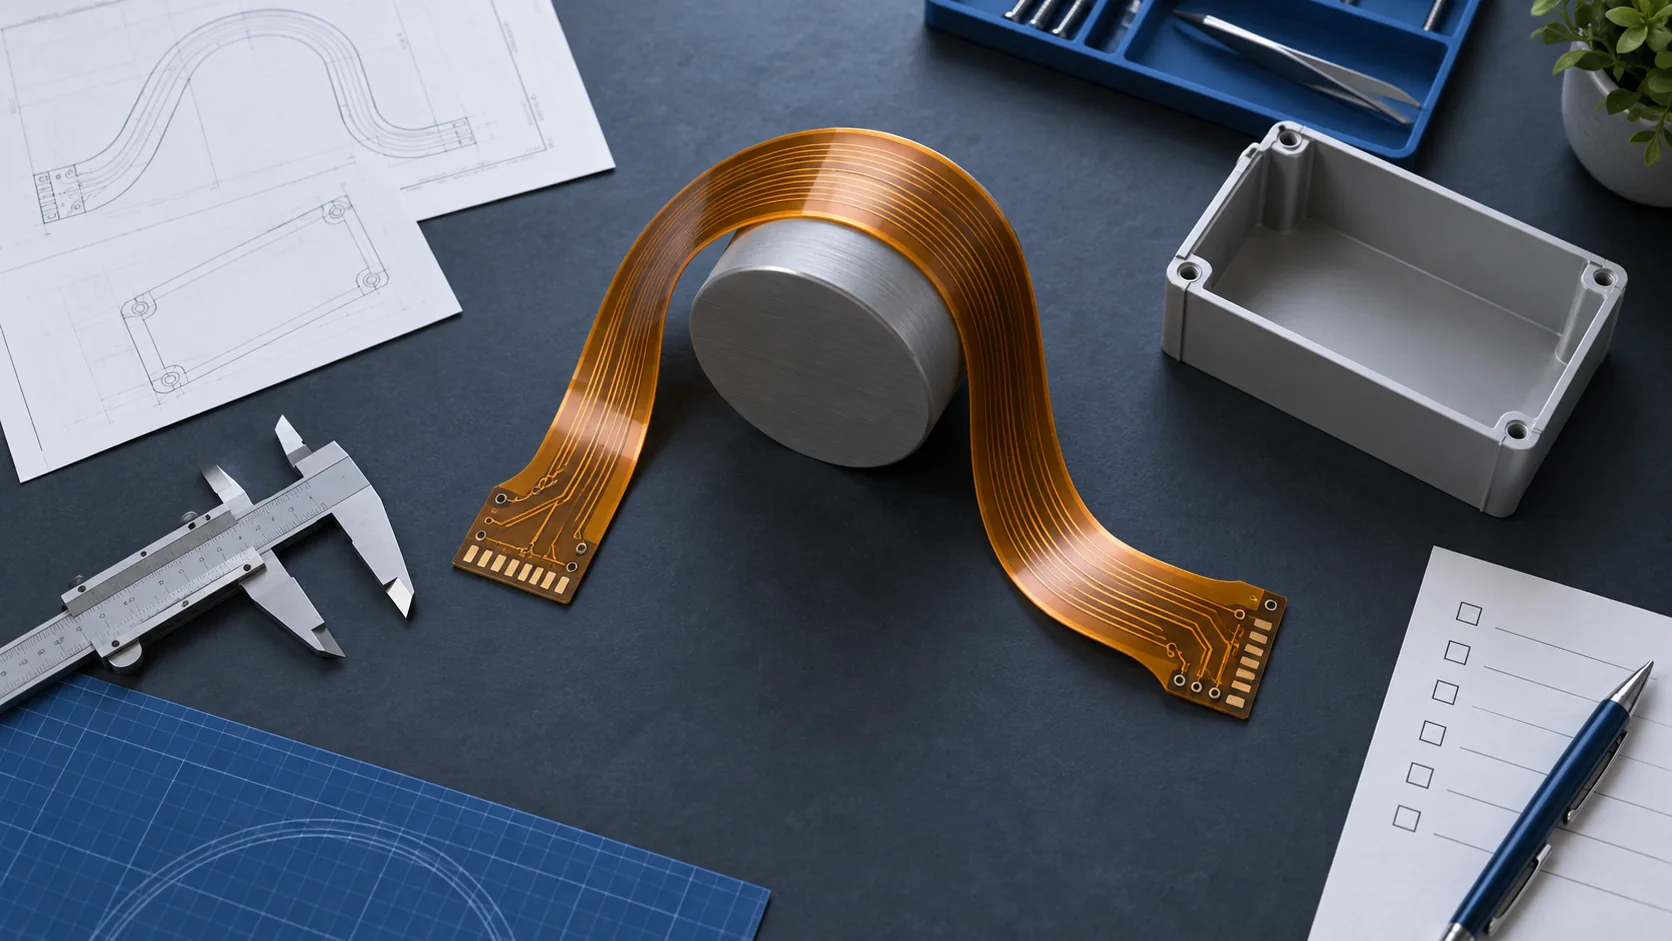
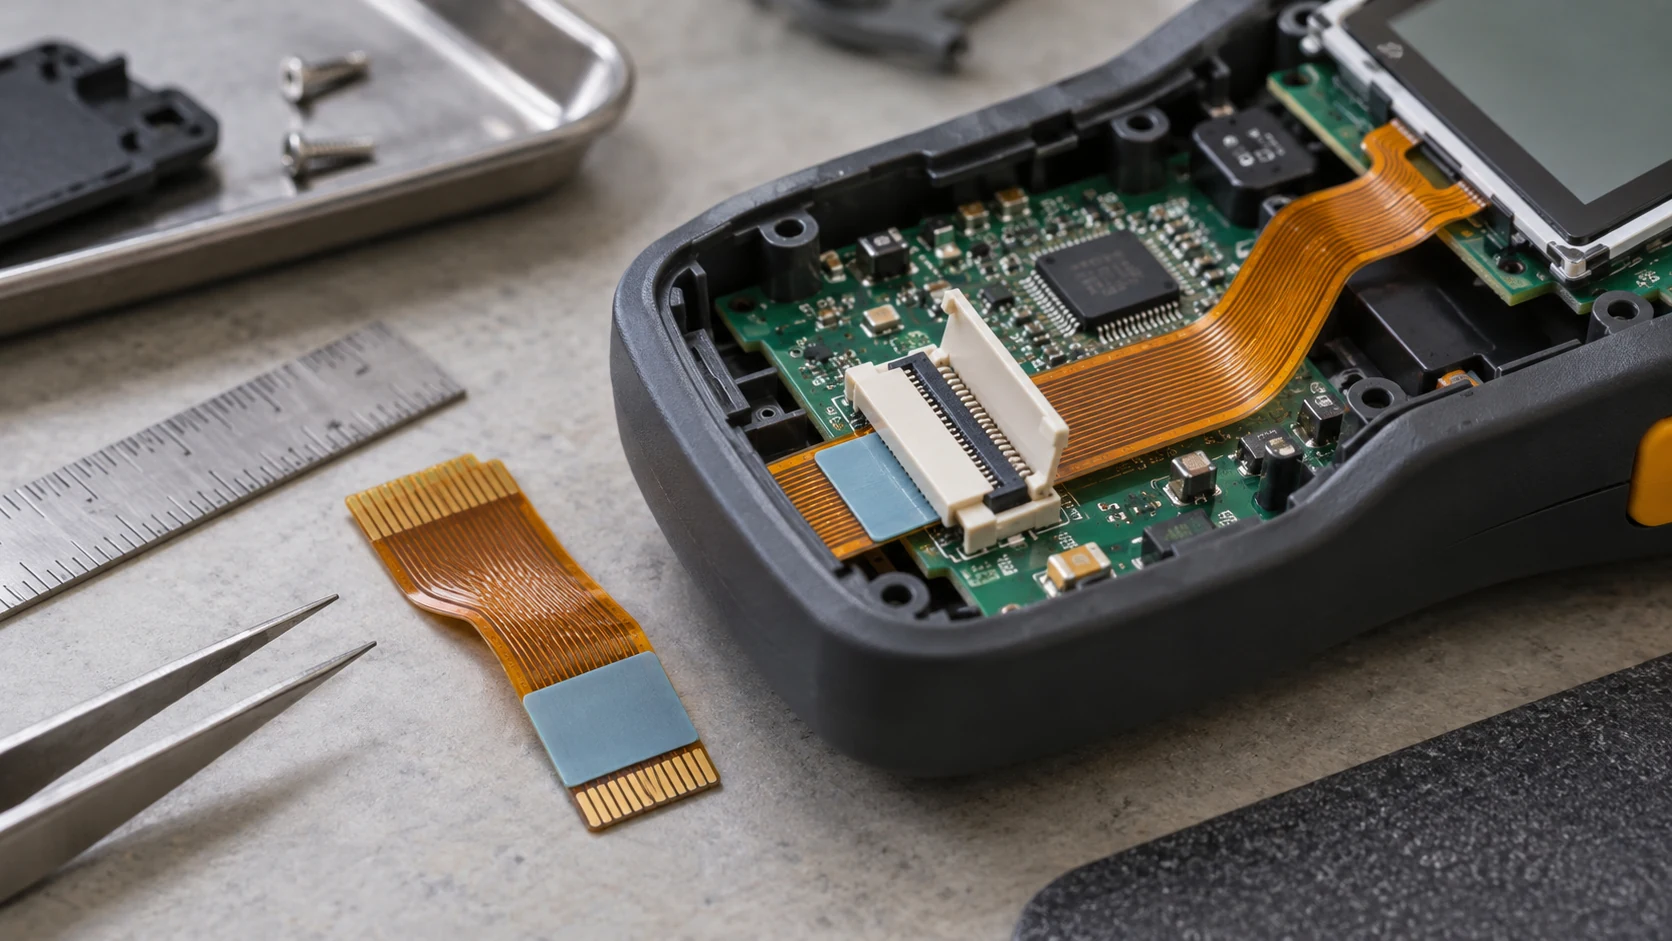
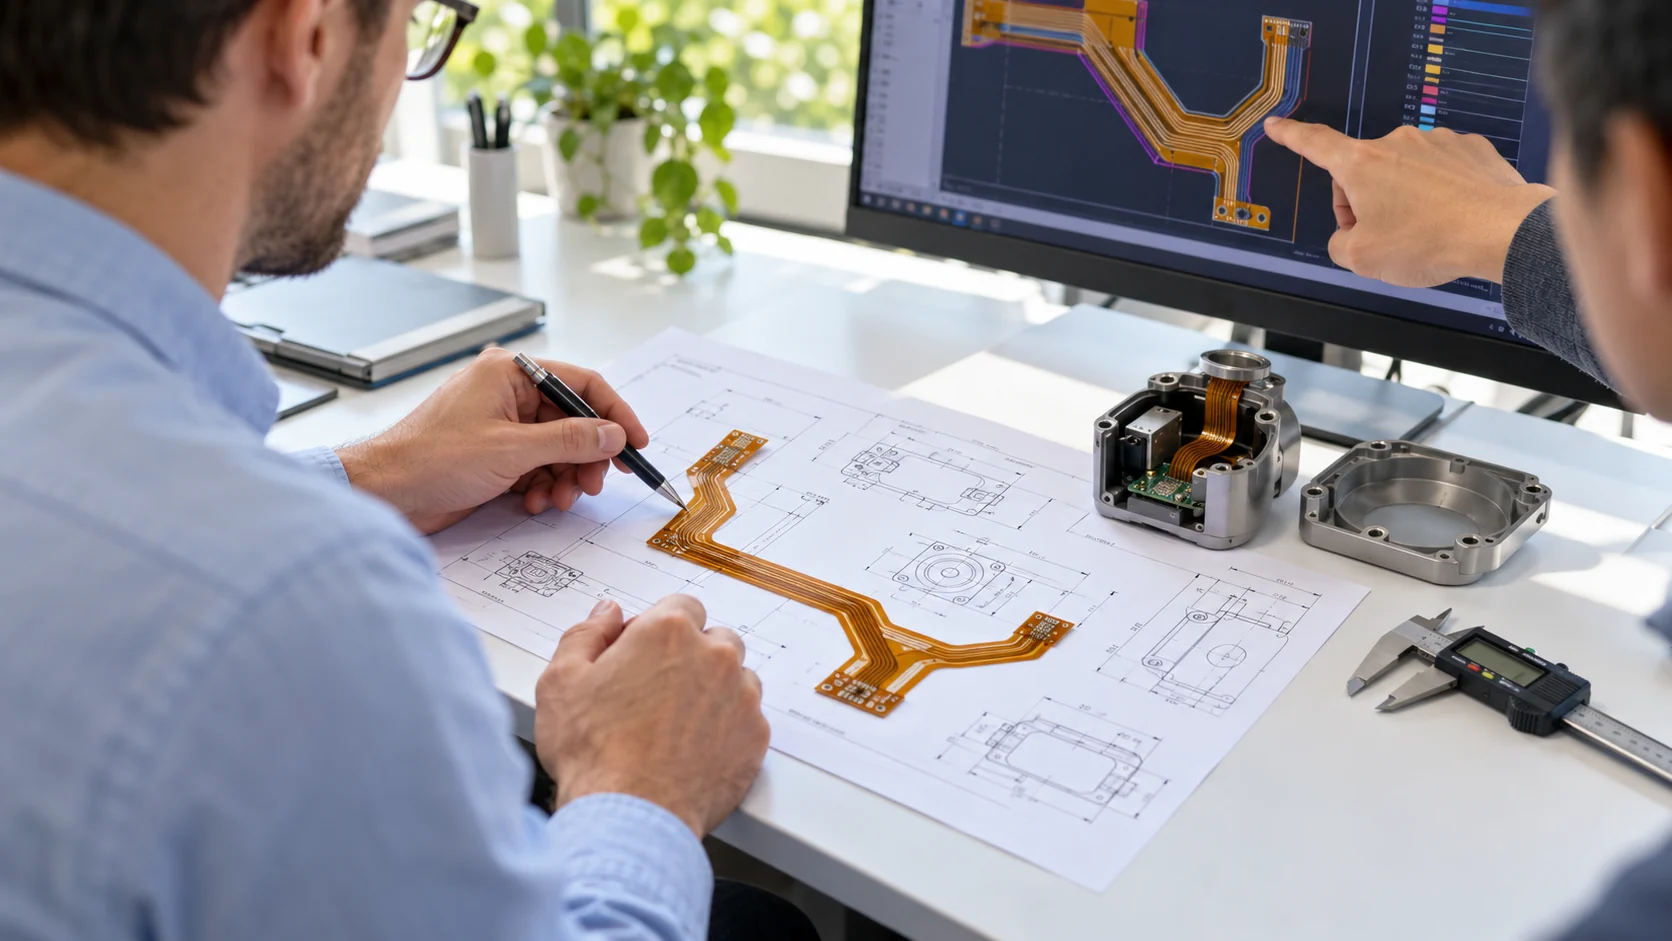
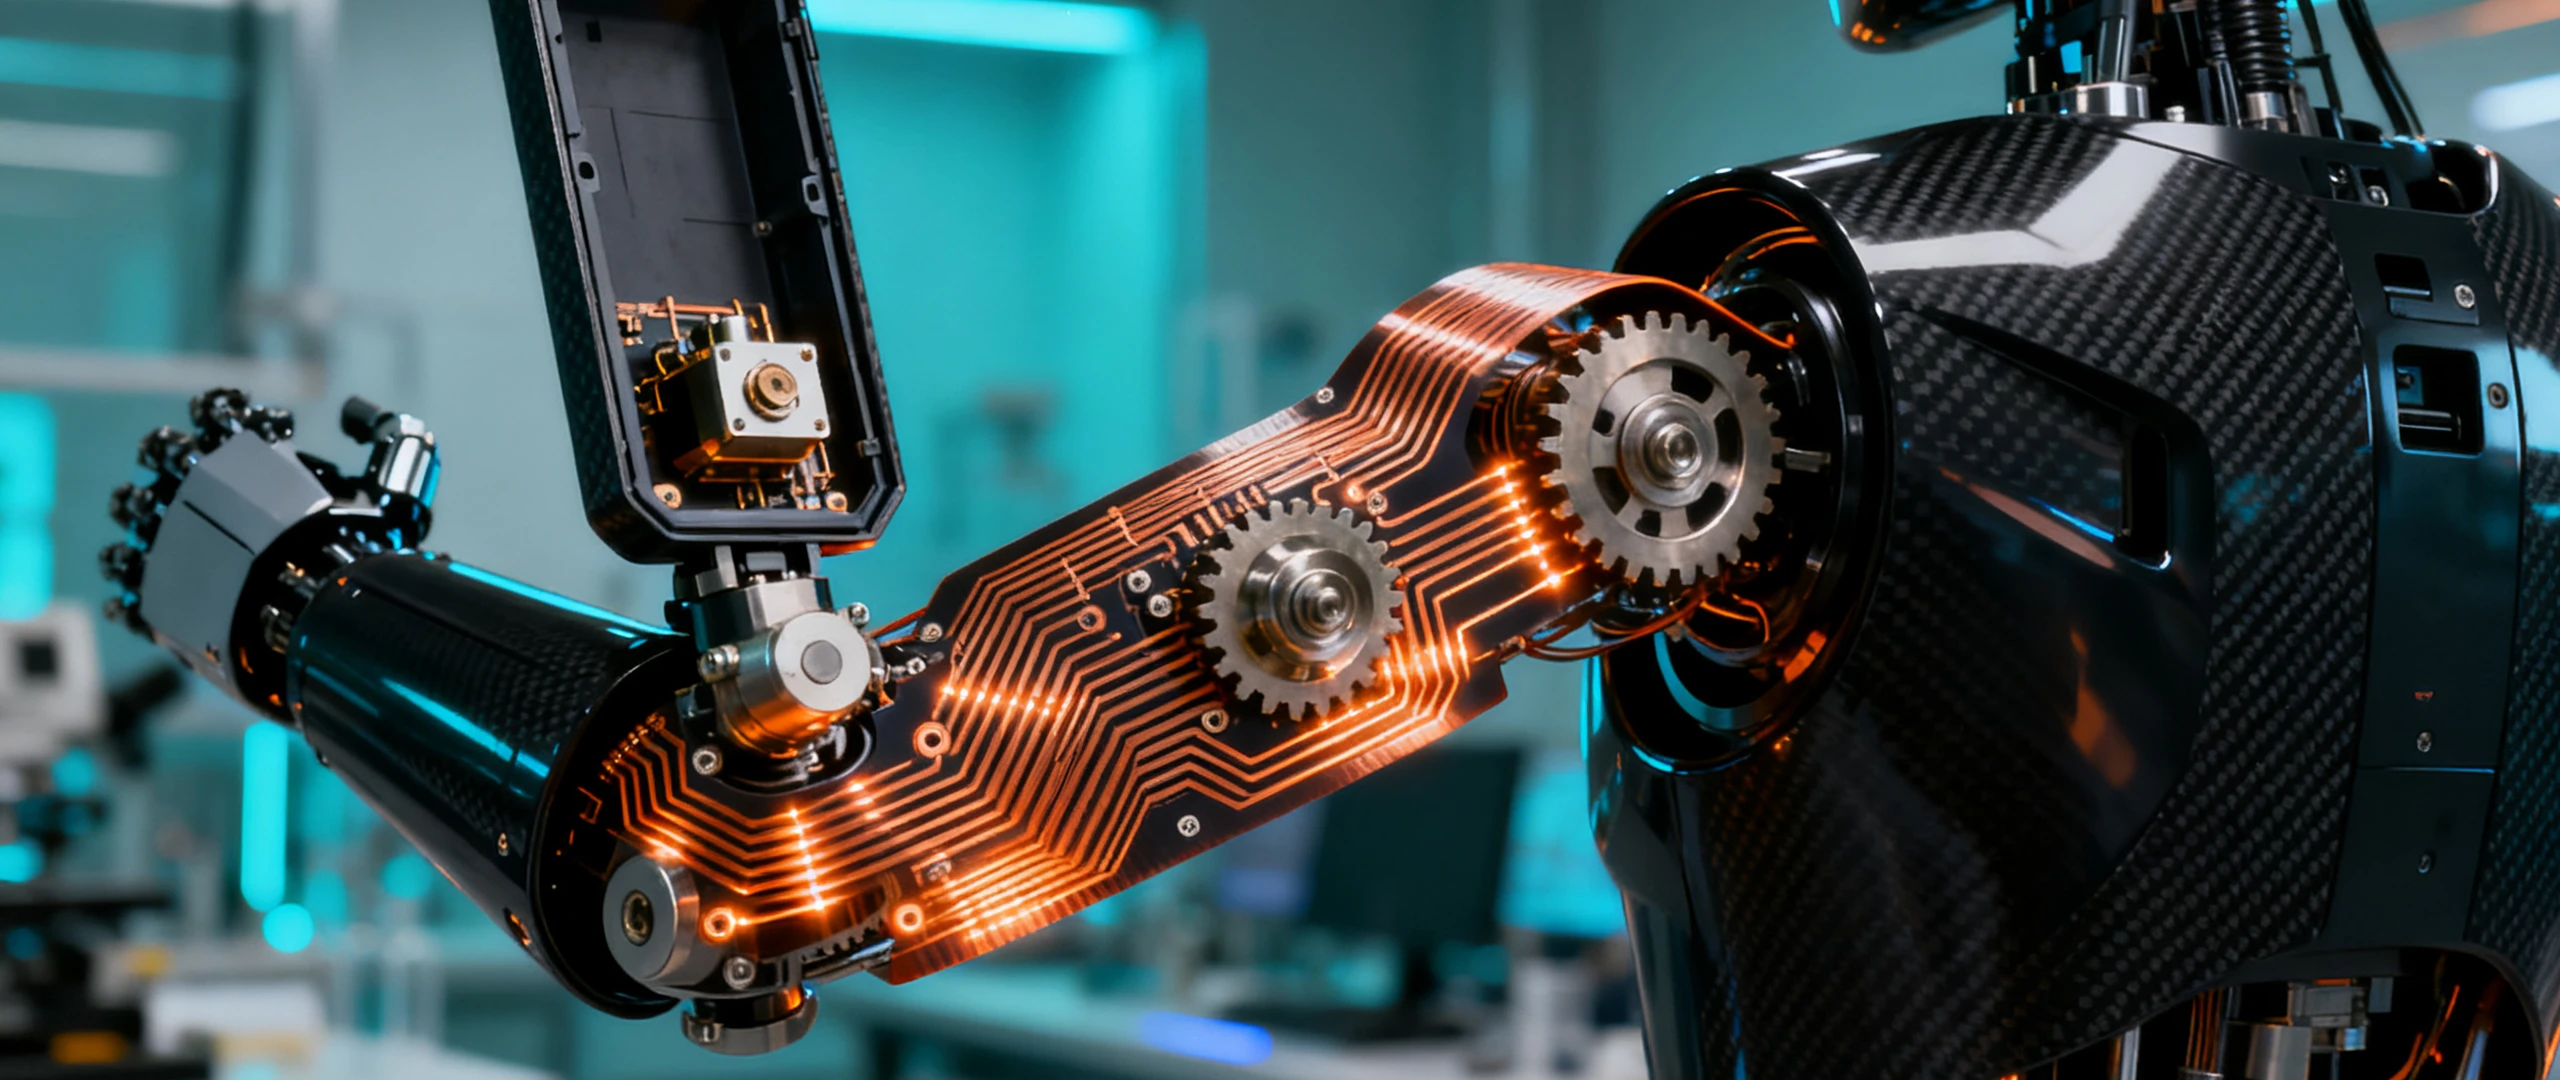
Define the full travel of robotic joints and grippers, the bend route and fixed support points. Select the construction and validation method around the actual mechanism instead of relying on a generic bending-cycle claim.